APPLICATIONSApplications grounded in engineering needs.
Our initial business development focus is spacecraft rendezvous and proximity operations, supported by GN&C, modeling, simulation, and failure-mode analysis. Broader aerospace and robotics areas remain potential project domains where expertise and customer demand align.
 Reference imagery: NASA/JPL-Caltech · source ↗
AERIAL & AEROSPACE AUTONOMYAutonomous flight systems
Guidance, control, planning, resilient navigation, and safety-aware autonomy for aerial and aerospace vehicles operating under uncertainty and constraints.
 Reference imagery: NASA/JPL-Caltech · source ↗
COOPERATIVE ROBOTICSNetworked robot teams
Safe formation, consensus, obstacle avoidance, heterogeneous dynamics, decentralized decision-making, and scalable coordination for teams of robots.
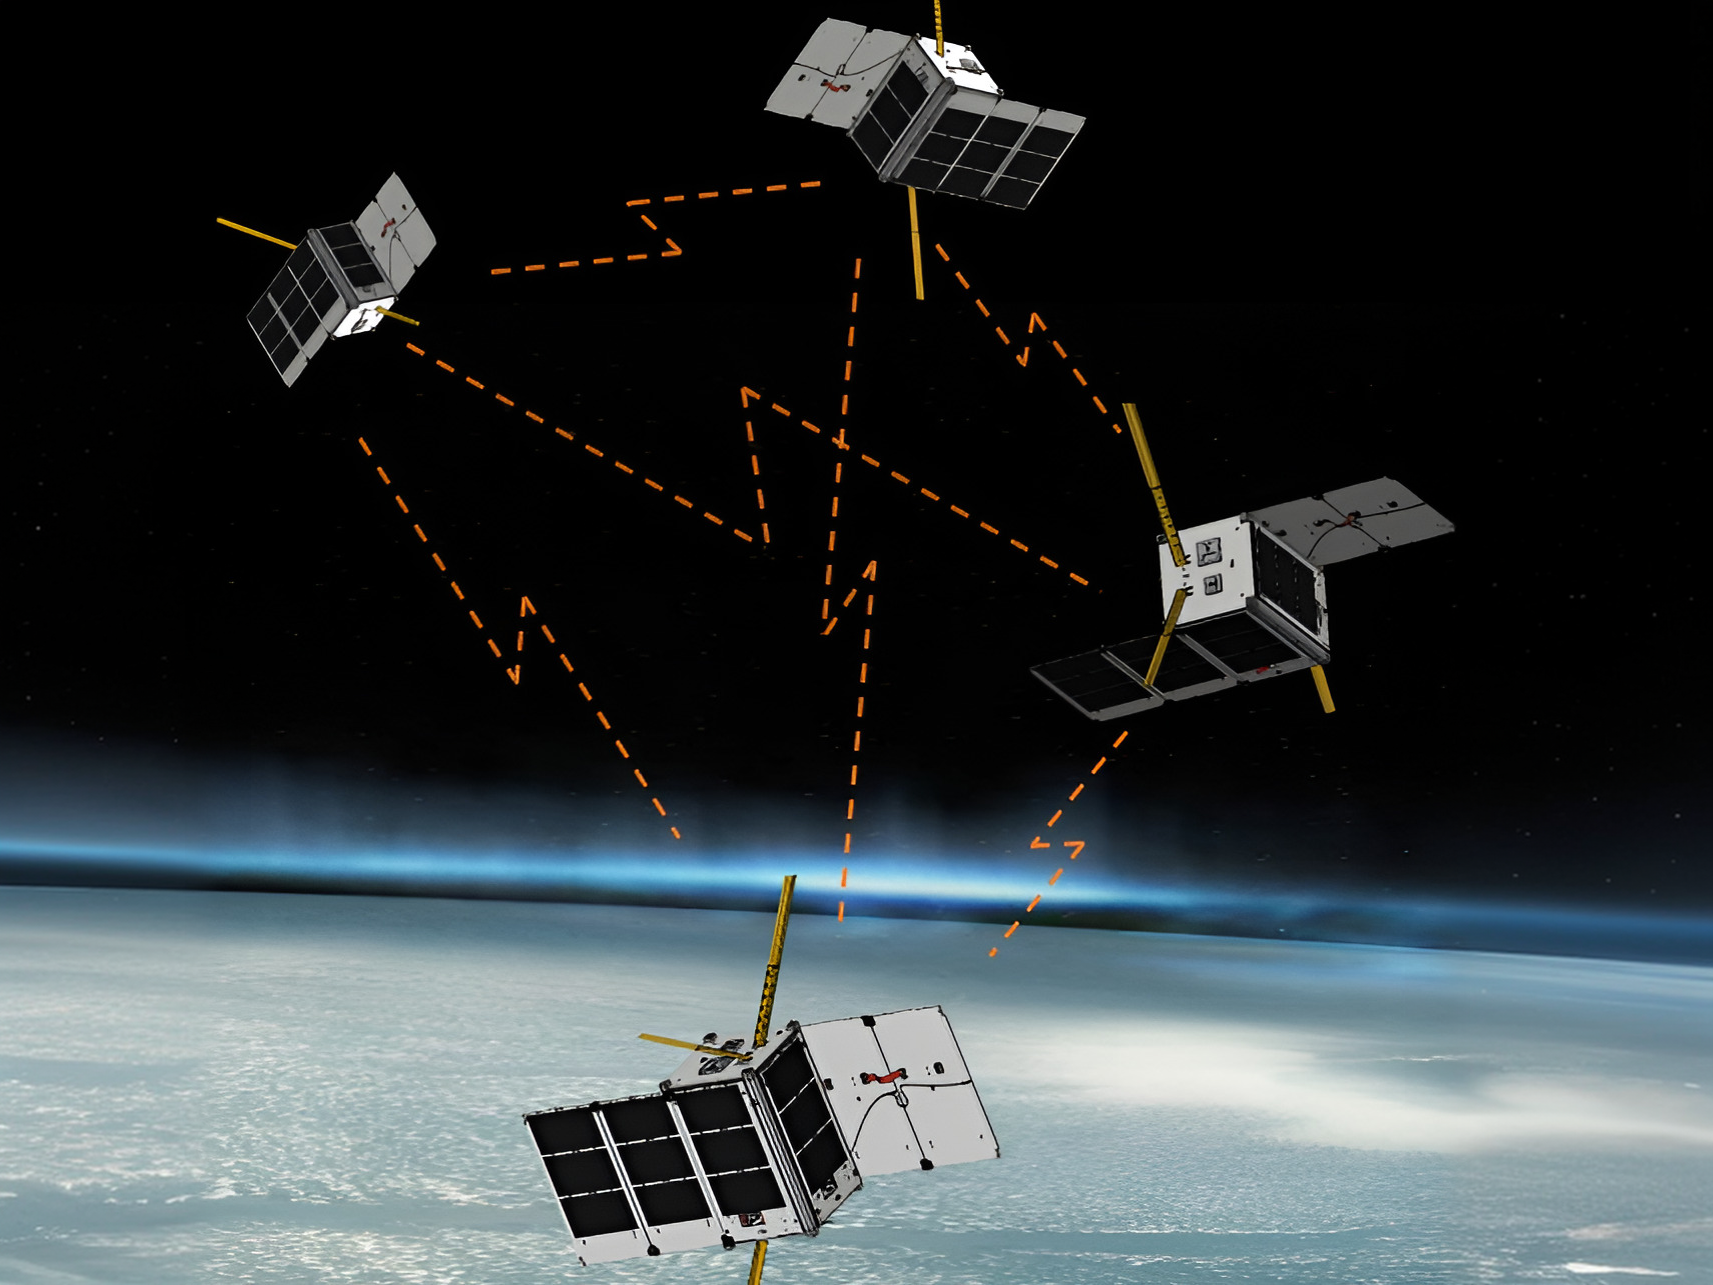 Reference imagery: spacecraft formation visualization · source ↗
DISTRIBUTED SPACE SYSTEMSSpacecraft formations & networked agents
Leader-follower coordination, formation keeping, distributed estimation and control, switching communication topologies, and safety-aware proximity operations.
04 / R&D TOOLING
Simulation, verification &
algorithm prototyping.
Build confidence before hardware integration.
Zoyem Labs develops modeling environments and numerical studies to investigate safety margins, robustness, scalability, communication effects, and computational tradeoffs—supporting disciplined progression from theory to implementable autonomy.
From research challenge to technical work package.
Zoyem Labs supports research formulation, control algorithm development, simulation studies, and verification-oriented analysis for safety-critical autonomous and multi-agent systems. Discuss your technical objectives, constraints, and proposed deliverables with our team.
Discuss Your Technical Requirements →These are capability and research directions, not claims that Zoyem LLC has performed work for any specific government agency or program.